Introduction #
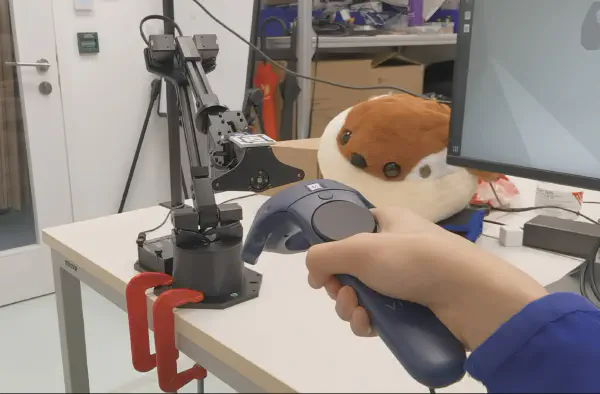
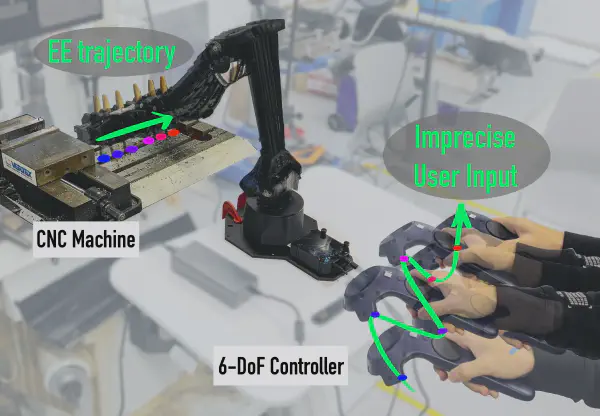
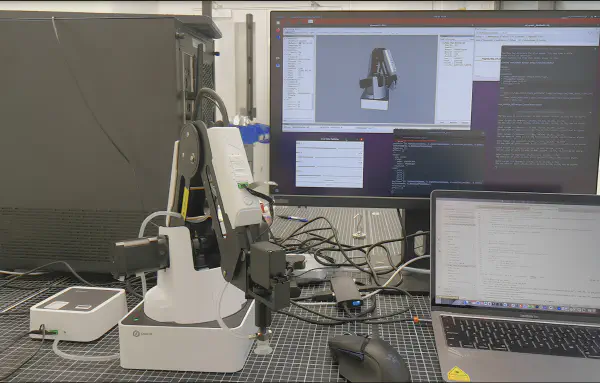
This project provides a ROS2 hardware interface, URDF model, and MoveIt configuration for controlling a 6-DoF robotic arm using Feetech motors. The 3D model is currently in beta and pending open-source release by Simple Automation.
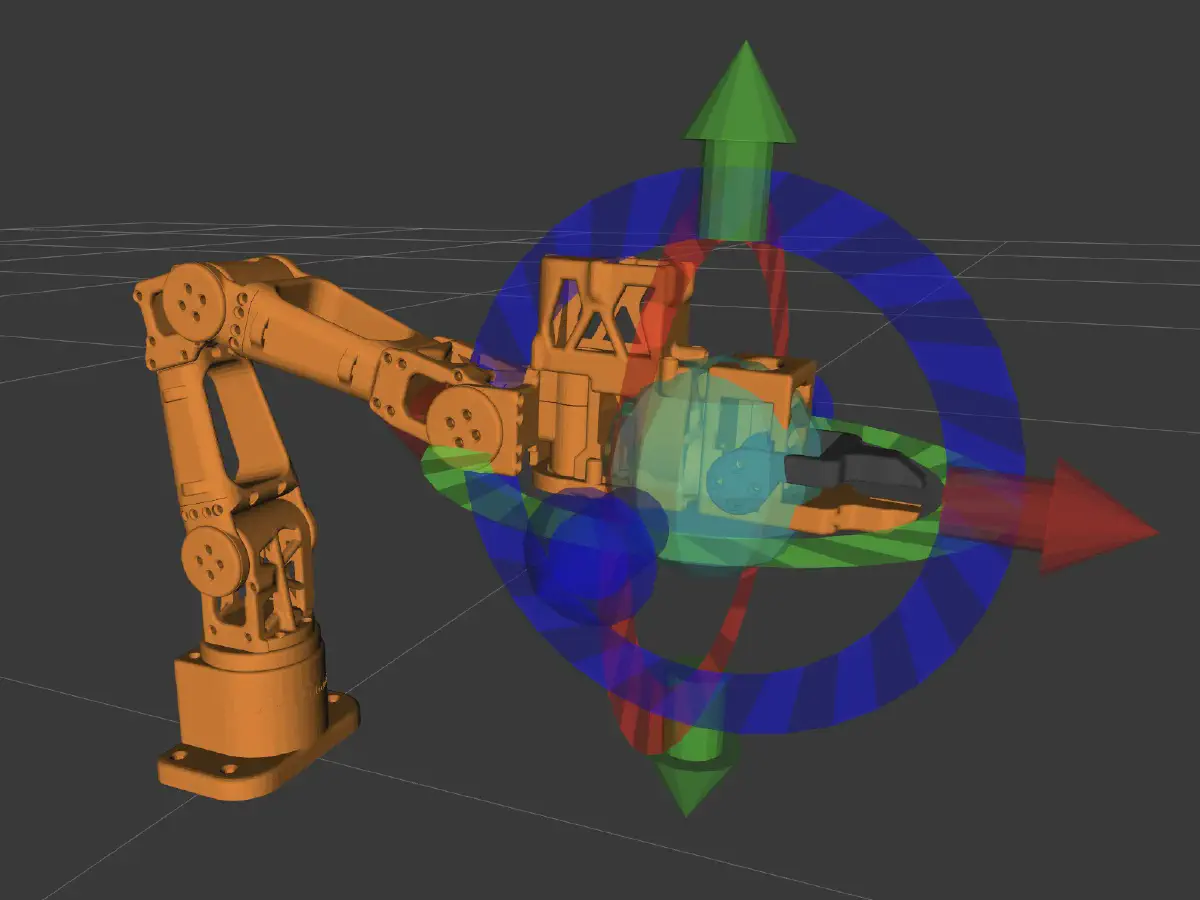
This project provides a ROS2 hardware interface, URDF model, and MoveIt configuration for controlling a 6-DoF robotic arm using Feetech motors. The 3D model is currently in beta and pending open-source release by Simple Automation.