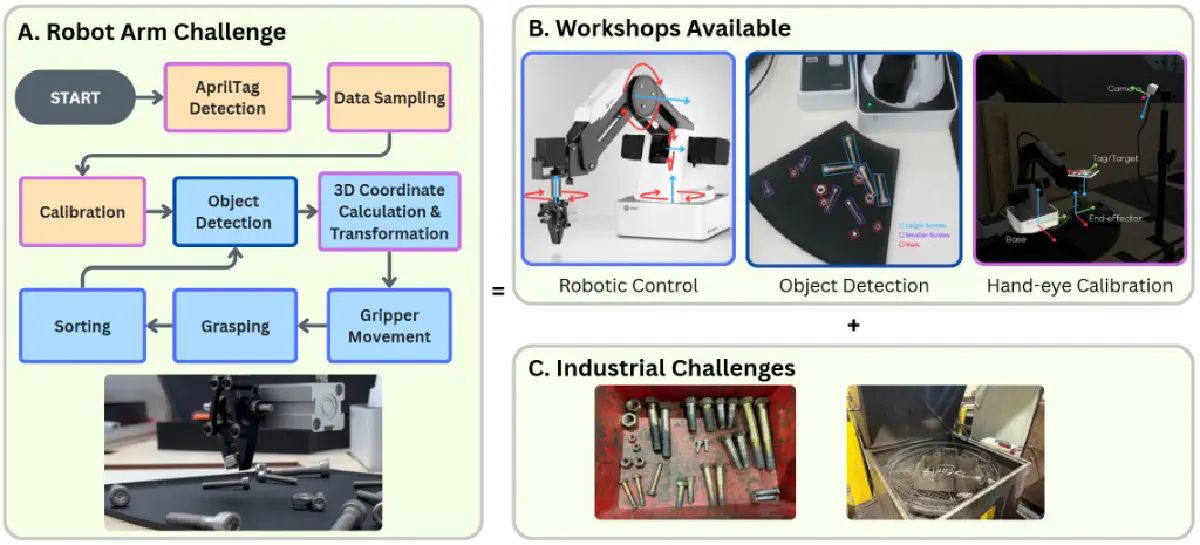
I teach and help run the Robot Arm Challenge at the HKU Innovation Wing. Students build an autonomous random bin-picking system: program a robot arm in Python, calibrate a camera to the arm (hand-eye calibration), and detect objects with an AI model.
The challenge is inspired by an industrial collaborator’s use case: sorting dirty screws and nuts before they go into a cleaning process. It has successfully run for three seasons: Spring 2025, Fall 2025, and Spring 2026. It grew from university junior-year workshops to a wider audience, including high-school students and industrial collaborators.
On 11 December 2025, a group of S4–S6 secondary school students joined a Smart Robotic Arm Workshop at the Innovation Wing. They learned the basics of robotic system integration and, with an AI detection model, completed a screw-picking task.